How It Works
The OSHE Pick and Place is an open-source hardware project of the Open Source Hardware Enterprise (oshe.io) at Michigan Tech.
The machine moves a single vacuum nozzle over a fixed plate. The board sits on the plate, the tape feeders sit at the front, and two cameras tell the software exactly where everything is.
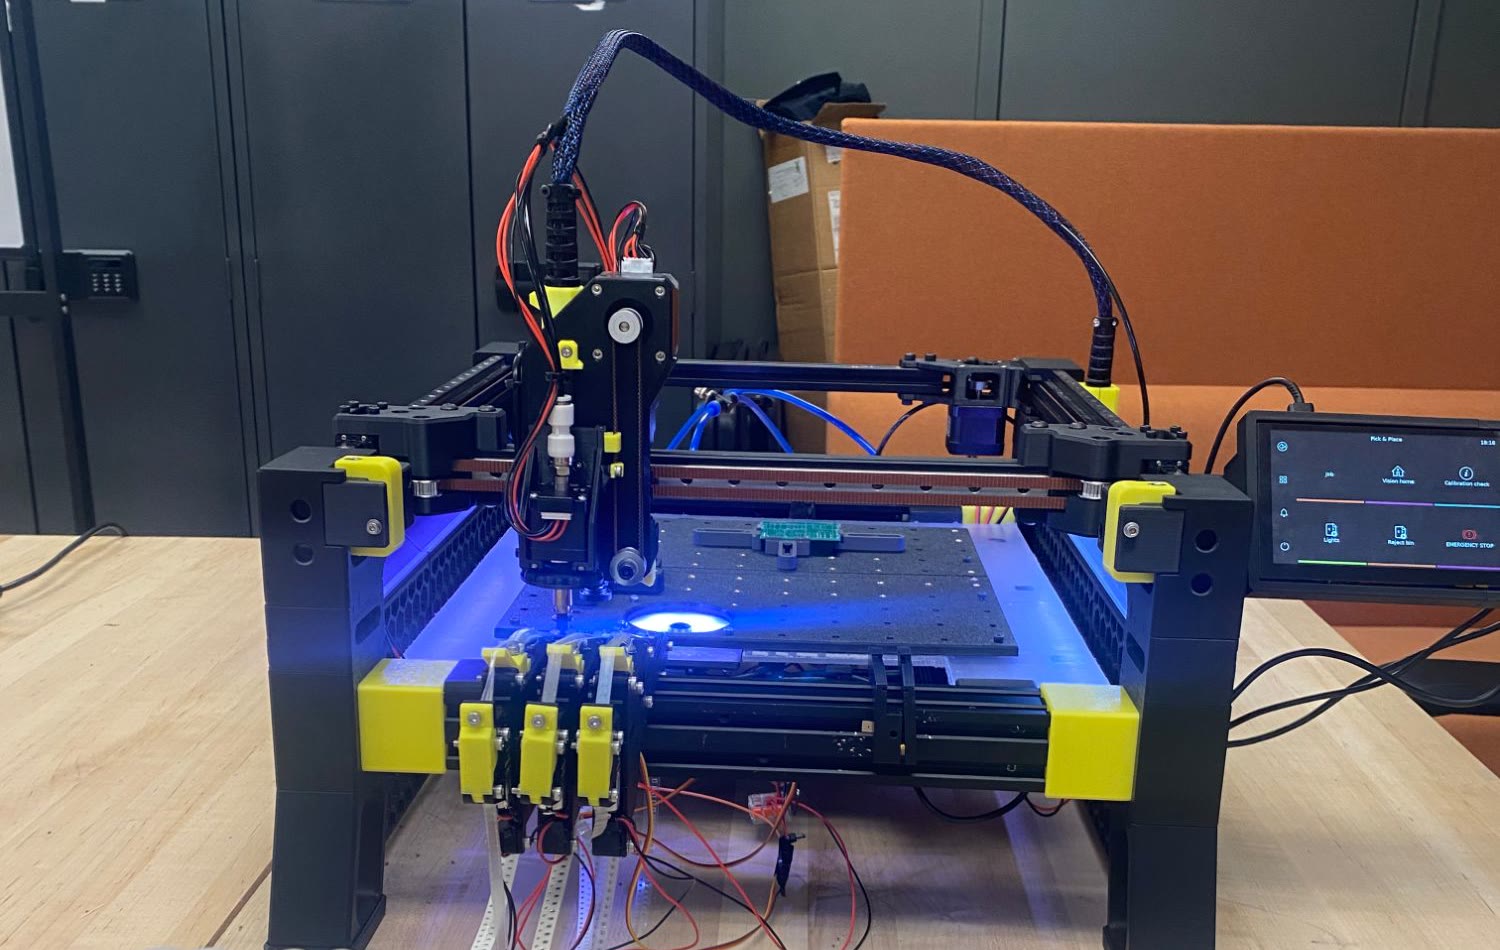
The parts of the machine
| Subsystem | What it is |
|---|---|
| Frame | Ender 3 aluminum extrusion with 3D-printed legs and corners |
| Motion | CoreXY (two motors share X and Y through crossed belts), Z for nozzle height, a small stepper to turn the nozzle |
| Toolhead | LumenPnP-style holder for Samsung CP40 nozzle tips, NEMA 11 rotation motor, down camera, LEDs |
| Staging plate | Printed tiles holding the PCB mounts, the camera datum (reference grid), the reject bin and the up camera |
| Cameras | Down camera on the toolhead (finds the board, checks placed parts), up camera under the plate (checks the part on the nozzle) |
| Feeders | 0816-style tape feeders, each advanced by a hobby servo driven by an Arduino Uno |
| Pneumatics | Compressor and solenoid valve for the nozzle vacuum |
| Electronics | BTT Octopus Pro (motion), Arduino Uno (servos, lights), Raspberry Pi 4 (host), 7" touchscreen |
The software
| Program | Runs on | Job |
|---|---|---|
| pnpslice | your computer (Windows app or Python) | Reads a KiCad board, checks it, orders the parts, writes the job file |
| Klipper | Pi + Octopus Pro + Uno | Motion, steppers, servos, lights, G-code macros |
| Moonraker / Mainsail | Pi | Web API and web dashboard |
| KlipperScreen | Pi (touchscreen) | The machine's own screen, including the PnP Job page |
| crowsnest | Pi | Streams both cameras |
| pnpvision | Pi | Calibration, visual homing, board alignment, the job runner, logging and reports |
One part, step by step
- Feed: the servo advances the tape by one pocket.
- Pick: the nozzle drops onto the part and the vacuum switches on.
- Inspect: the nozzle stops over the up camera. pnpvision measures the part's size, offset and angle. A wrong part, an empty nozzle, a part on its side or upside down is rejected.
- Correct and place: the nozzle turns to the right angle, moves to the board position plus the measured offset, lowers, releases the vacuum and lifts.
- Rejected parts go to the reject bin and the machine tries again (up to 3 picks).
Before the first part, the machine finds the board: the down camera visits the alignment pads chosen by pnpslice and fits the board's exact position and rotation.
Z runs upside down
Z = 0 is the top. A larger Z moves the nozzle lower. The nozzle touches the plate at about Z 50 and the top of a PCB at about Z 39.5.